Reorganizing library structure, prep for 2.0.0
This commit is contained in:
 Thomas Mørch
@@ -0,0 +1,317 @@
|
||||
/* An Alternative Software Serial Library
|
||||
* http://www.pjrc.com/teensy/td_libs_AltSoftSerial.html
|
||||
* Copyright (c) 2014 PJRC.COM, LLC, Paul Stoffregen, paul@pjrc.com
|
||||
*
|
||||
* Permission is hereby granted, free of charge, to any person obtaining a copy
|
||||
* of this software and associated documentation files (the "Software"), to deal
|
||||
* in the Software without restriction, including without limitation the rights
|
||||
* to use, copy, modify, merge, publish, distribute, sublicense, and/or sell
|
||||
* copies of the Software, and to permit persons to whom the Software is
|
||||
* furnished to do so, subject to the following conditions:
|
||||
*
|
||||
* The above copyright notice and this permission notice shall be included in
|
||||
* all copies or substantial portions of the Software.
|
||||
*
|
||||
* THE SOFTWARE IS PROVIDED "AS IS", WITHOUT WARRANTY OF ANY KIND, EXPRESS OR
|
||||
* IMPLIED, INCLUDING BUT NOT LIMITED TO THE WARRANTIES OF MERCHANTABILITY,
|
||||
* FITNESS FOR A PARTICULAR PURPOSE AND NONINFRINGEMENT. IN NO EVENT SHALL THE
|
||||
* AUTHORS OR COPYRIGHT HOLDERS BE LIABLE FOR ANY CLAIM, DAMAGES OR OTHER
|
||||
* LIABILITY, WHETHER IN AN ACTION OF CONTRACT, TORT OR OTHERWISE, ARISING FROM,
|
||||
* OUT OF OR IN CONNECTION WITH THE SOFTWARE OR THE USE OR OTHER DEALINGS IN
|
||||
* THE SOFTWARE.
|
||||
*/
|
||||
|
||||
// Version 1.2: Support Teensy 3.x
|
||||
//
|
||||
// Version 1.1: Improve performance in receiver code
|
||||
//
|
||||
// Version 1.0: Initial Release
|
||||
|
||||
|
||||
#include "AltSoftSerial.h"
|
||||
#include "config/AltSoftSerial_Boards.h"
|
||||
#include "config/AltSoftSerial_Timers.h"
|
||||
|
||||
/****************************************/
|
||||
/** Initialization **/
|
||||
/****************************************/
|
||||
|
||||
static uint16_t ticks_per_bit=0;
|
||||
bool AltSoftSerial::timing_error=false;
|
||||
|
||||
static uint8_t rx_state;
|
||||
static uint8_t rx_byte;
|
||||
static uint8_t rx_bit = 0;
|
||||
static uint16_t rx_target;
|
||||
static uint16_t rx_stop_ticks=0;
|
||||
static volatile uint8_t rx_buffer_head;
|
||||
static volatile uint8_t rx_buffer_tail;
|
||||
#define RX_BUFFER_SIZE 80
|
||||
static volatile uint8_t rx_buffer[RX_BUFFER_SIZE];
|
||||
|
||||
static volatile uint8_t tx_state=0;
|
||||
static uint8_t tx_byte;
|
||||
static uint8_t tx_bit;
|
||||
static volatile uint8_t tx_buffer_head;
|
||||
static volatile uint8_t tx_buffer_tail;
|
||||
#define TX_BUFFER_SIZE 68
|
||||
static volatile uint8_t tx_buffer[RX_BUFFER_SIZE];
|
||||
|
||||
|
||||
#ifndef INPUT_PULLUP
|
||||
#define INPUT_PULLUP INPUT
|
||||
#endif
|
||||
|
||||
void AltSoftSerial::init(uint32_t cycles_per_bit)
|
||||
{
|
||||
if (cycles_per_bit < 7085) {
|
||||
CONFIG_TIMER_NOPRESCALE();
|
||||
} else {
|
||||
cycles_per_bit /= 8;
|
||||
if (cycles_per_bit < 7085) {
|
||||
CONFIG_TIMER_PRESCALE_8();
|
||||
} else {
|
||||
return; // minimum 283 baud at 16 MHz clock
|
||||
}
|
||||
}
|
||||
ticks_per_bit = cycles_per_bit;
|
||||
rx_stop_ticks = cycles_per_bit * 37 / 4;
|
||||
pinMode(INPUT_CAPTURE_PIN, INPUT_PULLUP);
|
||||
digitalWrite(OUTPUT_COMPARE_A_PIN, HIGH);
|
||||
pinMode(OUTPUT_COMPARE_A_PIN, OUTPUT);
|
||||
rx_state = 0;
|
||||
rx_buffer_head = 0;
|
||||
rx_buffer_tail = 0;
|
||||
tx_state = 0;
|
||||
tx_buffer_head = 0;
|
||||
tx_buffer_tail = 0;
|
||||
ENABLE_INT_INPUT_CAPTURE();
|
||||
}
|
||||
|
||||
void AltSoftSerial::end(void)
|
||||
{
|
||||
DISABLE_INT_COMPARE_B();
|
||||
DISABLE_INT_INPUT_CAPTURE();
|
||||
flushInput();
|
||||
flushOutput();
|
||||
DISABLE_INT_COMPARE_A();
|
||||
// TODO: restore timer to original settings?
|
||||
}
|
||||
|
||||
|
||||
/****************************************/
|
||||
/** Transmission **/
|
||||
/****************************************/
|
||||
|
||||
void AltSoftSerial::writeByte(uint8_t b)
|
||||
{
|
||||
uint8_t intr_state, head;
|
||||
|
||||
head = tx_buffer_head + 1;
|
||||
if (head >= TX_BUFFER_SIZE) head = 0;
|
||||
while (tx_buffer_tail == head) ; // wait until space in buffer
|
||||
intr_state = SREG;
|
||||
cli();
|
||||
if (tx_state) {
|
||||
tx_buffer[head] = b;
|
||||
tx_buffer_head = head;
|
||||
} else {
|
||||
tx_state = 1;
|
||||
tx_byte = b;
|
||||
tx_bit = 0;
|
||||
ENABLE_INT_COMPARE_A();
|
||||
CONFIG_MATCH_CLEAR();
|
||||
SET_COMPARE_A(GET_TIMER_COUNT() + 16);
|
||||
}
|
||||
SREG = intr_state;
|
||||
}
|
||||
|
||||
|
||||
ISR(COMPARE_A_INTERRUPT)
|
||||
{
|
||||
uint8_t state, byte, bit, head, tail;
|
||||
uint16_t target;
|
||||
|
||||
state = tx_state;
|
||||
byte = tx_byte;
|
||||
target = GET_COMPARE_A();
|
||||
while (state < 9) {
|
||||
target += ticks_per_bit;
|
||||
bit = byte & 1;
|
||||
byte >>= 1;
|
||||
state++;
|
||||
if (bit != tx_bit) {
|
||||
if (bit) {
|
||||
CONFIG_MATCH_SET();
|
||||
} else {
|
||||
CONFIG_MATCH_CLEAR();
|
||||
}
|
||||
SET_COMPARE_A(target);
|
||||
tx_bit = bit;
|
||||
tx_byte = byte;
|
||||
tx_state = state;
|
||||
// TODO: how to detect timing_error?
|
||||
return;
|
||||
}
|
||||
}
|
||||
if (state == 9) {
|
||||
tx_state = 10;
|
||||
CONFIG_MATCH_SET();
|
||||
SET_COMPARE_A(target + ticks_per_bit);
|
||||
return;
|
||||
}
|
||||
head = tx_buffer_head;
|
||||
tail = tx_buffer_tail;
|
||||
if (head == tail) {
|
||||
tx_state = 0;
|
||||
CONFIG_MATCH_NORMAL();
|
||||
DISABLE_INT_COMPARE_A();
|
||||
} else {
|
||||
tx_state = 1;
|
||||
if (++tail >= TX_BUFFER_SIZE) tail = 0;
|
||||
tx_buffer_tail = tail;
|
||||
tx_byte = tx_buffer[tail];
|
||||
tx_bit = 0;
|
||||
CONFIG_MATCH_CLEAR();
|
||||
SET_COMPARE_A(target + ticks_per_bit);
|
||||
// TODO: how to detect timing_error?
|
||||
}
|
||||
}
|
||||
|
||||
void AltSoftSerial::flushOutput(void)
|
||||
{
|
||||
while (tx_state) /* wait */ ;
|
||||
}
|
||||
|
||||
|
||||
/****************************************/
|
||||
/** Reception **/
|
||||
/****************************************/
|
||||
|
||||
|
||||
ISR(CAPTURE_INTERRUPT)
|
||||
{
|
||||
uint8_t state, bit, head;
|
||||
uint16_t capture, target;
|
||||
int16_t offset;
|
||||
|
||||
capture = GET_INPUT_CAPTURE();
|
||||
bit = rx_bit;
|
||||
if (bit) {
|
||||
CONFIG_CAPTURE_FALLING_EDGE();
|
||||
rx_bit = 0;
|
||||
} else {
|
||||
CONFIG_CAPTURE_RISING_EDGE();
|
||||
rx_bit = 0x80;
|
||||
}
|
||||
state = rx_state;
|
||||
if (state == 0) {
|
||||
if (!bit) {
|
||||
SET_COMPARE_B(capture + rx_stop_ticks);
|
||||
ENABLE_INT_COMPARE_B();
|
||||
rx_target = capture + ticks_per_bit + ticks_per_bit/2;
|
||||
rx_state = 1;
|
||||
}
|
||||
} else {
|
||||
target = rx_target;
|
||||
while (1) {
|
||||
offset = capture - target;
|
||||
if (offset < 0) break;
|
||||
rx_byte = (rx_byte >> 1) | rx_bit;
|
||||
target += ticks_per_bit;
|
||||
state++;
|
||||
if (state >= 9) {
|
||||
DISABLE_INT_COMPARE_B();
|
||||
head = rx_buffer_head + 1;
|
||||
if (head >= RX_BUFFER_SIZE) head = 0;
|
||||
if (head != rx_buffer_tail) {
|
||||
rx_buffer[head] = rx_byte;
|
||||
rx_buffer_head = head;
|
||||
}
|
||||
CONFIG_CAPTURE_FALLING_EDGE();
|
||||
rx_bit = 0;
|
||||
rx_state = 0;
|
||||
return;
|
||||
}
|
||||
}
|
||||
rx_target = target;
|
||||
rx_state = state;
|
||||
}
|
||||
//if (GET_TIMER_COUNT() - capture > ticks_per_bit) AltSoftSerial::timing_error = true;
|
||||
}
|
||||
|
||||
ISR(COMPARE_B_INTERRUPT)
|
||||
{
|
||||
uint8_t head, state, bit;
|
||||
|
||||
DISABLE_INT_COMPARE_B();
|
||||
CONFIG_CAPTURE_FALLING_EDGE();
|
||||
state = rx_state;
|
||||
bit = rx_bit ^ 0x80;
|
||||
while (state < 9) {
|
||||
rx_byte = (rx_byte >> 1) | bit;
|
||||
state++;
|
||||
}
|
||||
head = rx_buffer_head + 1;
|
||||
if (head >= RX_BUFFER_SIZE) head = 0;
|
||||
if (head != rx_buffer_tail) {
|
||||
rx_buffer[head] = rx_byte;
|
||||
rx_buffer_head = head;
|
||||
}
|
||||
rx_state = 0;
|
||||
CONFIG_CAPTURE_FALLING_EDGE();
|
||||
rx_bit = 0;
|
||||
}
|
||||
|
||||
|
||||
|
||||
int AltSoftSerial::read(void)
|
||||
{
|
||||
uint8_t head, tail, out;
|
||||
|
||||
head = rx_buffer_head;
|
||||
tail = rx_buffer_tail;
|
||||
if (head == tail) return -1;
|
||||
if (++tail >= RX_BUFFER_SIZE) tail = 0;
|
||||
out = rx_buffer[tail];
|
||||
rx_buffer_tail = tail;
|
||||
return out;
|
||||
}
|
||||
|
||||
int AltSoftSerial::peek(void)
|
||||
{
|
||||
uint8_t head, tail;
|
||||
|
||||
head = rx_buffer_head;
|
||||
tail = rx_buffer_tail;
|
||||
if (head == tail) return -1;
|
||||
return rx_buffer[tail];
|
||||
}
|
||||
|
||||
int AltSoftSerial::available(void)
|
||||
{
|
||||
uint8_t head, tail;
|
||||
|
||||
head = rx_buffer_head;
|
||||
tail = rx_buffer_tail;
|
||||
if (head >= tail) return head - tail;
|
||||
return RX_BUFFER_SIZE + head - tail;
|
||||
}
|
||||
|
||||
void AltSoftSerial::flushInput(void)
|
||||
{
|
||||
rx_buffer_head = rx_buffer_tail;
|
||||
}
|
||||
|
||||
|
||||
#ifdef ALTSS_USE_FTM0
|
||||
void ftm0_isr(void)
|
||||
{
|
||||
uint32_t flags = FTM0_STATUS;
|
||||
FTM0_STATUS = 0;
|
||||
if (flags & (1<<5)) altss_capture_interrupt();
|
||||
if (flags & (1<<6)) altss_compare_a_interrupt();
|
||||
if (flags & (1<<0)) altss_compare_b_interrupt();
|
||||
}
|
||||
#endif
|
||||
|
||||
@@ -0,0 +1,76 @@
|
||||
/* An Alternative Software Serial Library
|
||||
* http://www.pjrc.com/teensy/td_libs_AltSoftSerial.html
|
||||
* Copyright (c) 2014 PJRC.COM, LLC, Paul Stoffregen, paul@pjrc.com
|
||||
*
|
||||
* Permission is hereby granted, free of charge, to any person obtaining a copy
|
||||
* of this software and associated documentation files (the "Software"), to deal
|
||||
* in the Software without restriction, including without limitation the rights
|
||||
* to use, copy, modify, merge, publish, distribute, sublicense, and/or sell
|
||||
* copies of the Software, and to permit persons to whom the Software is
|
||||
* furnished to do so, subject to the following conditions:
|
||||
*
|
||||
* The above copyright notice and this permission notice shall be included in
|
||||
* all copies or substantial portions of the Software.
|
||||
*
|
||||
* THE SOFTWARE IS PROVIDED "AS IS", WITHOUT WARRANTY OF ANY KIND, EXPRESS OR
|
||||
* IMPLIED, INCLUDING BUT NOT LIMITED TO THE WARRANTIES OF MERCHANTABILITY,
|
||||
* FITNESS FOR A PARTICULAR PURPOSE AND NONINFRINGEMENT. IN NO EVENT SHALL THE
|
||||
* AUTHORS OR COPYRIGHT HOLDERS BE LIABLE FOR ANY CLAIM, DAMAGES OR OTHER
|
||||
* LIABILITY, WHETHER IN AN ACTION OF CONTRACT, TORT OR OTHERWISE, ARISING FROM,
|
||||
* OUT OF OR IN CONNECTION WITH THE SOFTWARE OR THE USE OR OTHER DEALINGS IN
|
||||
* THE SOFTWARE.
|
||||
*/
|
||||
|
||||
#ifndef AltSoftSerial_h
|
||||
#define AltSoftSerial_h
|
||||
|
||||
#include <inttypes.h>
|
||||
|
||||
#if ARDUINO >= 100
|
||||
#include "Arduino.h"
|
||||
#else
|
||||
#include "WProgram.h"
|
||||
#include "pins_arduino.h"
|
||||
#endif
|
||||
|
||||
#if defined(__arm__) && defined(CORE_TEENSY)
|
||||
#define ALTSS_BASE_FREQ F_BUS
|
||||
#else
|
||||
#define ALTSS_BASE_FREQ F_CPU
|
||||
#endif
|
||||
|
||||
/** AltSoftSerial class */
|
||||
class AltSoftSerial : public Stream
|
||||
{
|
||||
public:
|
||||
AltSoftSerial() { } //!< Constructor
|
||||
~AltSoftSerial() { end(); } //!< Destructor
|
||||
static void begin(uint32_t baud) { init((ALTSS_BASE_FREQ + baud / 2) / baud); } //!< begin
|
||||
static void end(); //!< end
|
||||
int peek(); //!< peek
|
||||
int read(); //!< read
|
||||
int available(); //!< available
|
||||
#if ARDUINO >= 100
|
||||
size_t write(uint8_t byte) { writeByte(byte); return 1; } //!< write
|
||||
void flush() { flushOutput(); } //!< flush
|
||||
#else
|
||||
void write(uint8_t byte) { writeByte(byte); } //!< write
|
||||
void flush() { flushInput(); } //!< flush
|
||||
#endif
|
||||
using Print::write;
|
||||
static void flushInput(); //!< flushInput
|
||||
static void flushOutput(); //!< flushOutput
|
||||
// for drop-in compatibility with NewSoftSerial, rxPin & txPin ignored
|
||||
//AltSoftSerial(uint8_t rxPin, uint8_t txPin, bool inverse = false) { }
|
||||
bool listen() { return false; } //!< listen
|
||||
bool isListening() { return true; } //!< isListening
|
||||
bool overflow() { bool r = timing_error; timing_error = false; return r; } //!< overflow
|
||||
static int library_version() { return 1; } //!< library_version
|
||||
static void enable_timer0(bool) { } //!< enable_timer0
|
||||
static bool timing_error; //!< timing_error
|
||||
private:
|
||||
static void init(uint32_t cycles_per_bit);
|
||||
static void writeByte(uint8_t byte);
|
||||
};
|
||||
|
||||
#endif
|
||||
@@ -0,0 +1,9 @@
|
||||
#AltSoftSerial Library#
|
||||
|
||||
Improved software emulated serial, using hardware timers for precise signal
|
||||
timing and availability of CPU time for other libraries to respond to interrupts
|
||||
during data AltSoftSerial data transmission and reception.
|
||||
|
||||
http://www.pjrc.com/teensy/td_libs_AltSoftSerial.html
|
||||
|
||||
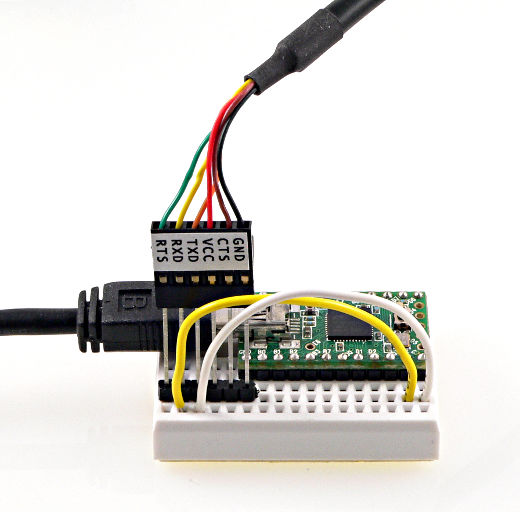
|
||||
@@ -0,0 +1,138 @@
|
||||
/* An Alternative Software Serial Library
|
||||
* http://www.pjrc.com/teensy/td_libs_AltSoftSerial.html
|
||||
* Copyright (c) 2014 PJRC.COM, LLC, Paul Stoffregen, paul@pjrc.com
|
||||
*
|
||||
* Permission is hereby granted, free of charge, to any person obtaining a copy
|
||||
* of this software and associated documentation files (the "Software"), to deal
|
||||
* in the Software without restriction, including without limitation the rights
|
||||
* to use, copy, modify, merge, publish, distribute, sublicense, and/or sell
|
||||
* copies of the Software, and to permit persons to whom the Software is
|
||||
* furnished to do so, subject to the following conditions:
|
||||
*
|
||||
* The above copyright notice and this permission notice shall be included in
|
||||
* all copies or substantial portions of the Software.
|
||||
*
|
||||
* THE SOFTWARE IS PROVIDED "AS IS", WITHOUT WARRANTY OF ANY KIND, EXPRESS OR
|
||||
* IMPLIED, INCLUDING BUT NOT LIMITED TO THE WARRANTIES OF MERCHANTABILITY,
|
||||
* FITNESS FOR A PARTICULAR PURPOSE AND NONINFRINGEMENT. IN NO EVENT SHALL THE
|
||||
* AUTHORS OR COPYRIGHT HOLDERS BE LIABLE FOR ANY CLAIM, DAMAGES OR OTHER
|
||||
* LIABILITY, WHETHER IN AN ACTION OF CONTRACT, TORT OR OTHERWISE, ARISING FROM,
|
||||
* OUT OF OR IN CONNECTION WITH THE SOFTWARE OR THE USE OR OTHER DEALINGS IN
|
||||
* THE SOFTWARE.
|
||||
*/
|
||||
|
||||
|
||||
// Teensy 2.0
|
||||
//
|
||||
#if defined(__AVR_ATmega32U4__) && defined(CORE_TEENSY)
|
||||
|
||||
//#define ALTSS_USE_TIMER1
|
||||
//#define INPUT_CAPTURE_PIN 22 // receive
|
||||
//#define OUTPUT_COMPARE_A_PIN 14 // transmit
|
||||
//#define OUTPUT_COMPARE_B_PIN 15 // unusable PWM
|
||||
//#define OUTPUT_COMPARE_C_PIN 4 // unusable PWM
|
||||
|
||||
#define ALTSS_USE_TIMER3
|
||||
#define INPUT_CAPTURE_PIN 10 // receive
|
||||
#define OUTPUT_COMPARE_A_PIN 9 // transmit
|
||||
|
||||
|
||||
|
||||
// Teensy++ 2.0
|
||||
//
|
||||
#elif defined(__AVR_AT90USB1286__) && defined(CORE_TEENSY)
|
||||
|
||||
#define ALTSS_USE_TIMER1
|
||||
#define INPUT_CAPTURE_PIN 4 // receive
|
||||
#define OUTPUT_COMPARE_A_PIN 25 // transmit
|
||||
#define OUTPUT_COMPARE_B_PIN 26 // unusable PWM
|
||||
#define OUTPUT_COMPARE_C_PIN 27 // unusable PWM
|
||||
|
||||
//#define ALTSS_USE_TIMER3
|
||||
//#define INPUT_CAPTURE_PIN 17 // receive
|
||||
//#define OUTPUT_COMPARE_A_PIN 16 // transmit
|
||||
//#define OUTPUT_COMPARE_B_PIN 15 // unusable PWM
|
||||
//#define OUTPUT_COMPARE_C_PIN 14 // unusable PWM
|
||||
|
||||
|
||||
// Teensy 3.0 & 3.1
|
||||
//
|
||||
#elif defined(__MK20DX128__) || defined(__MK20DX256__)
|
||||
#define ALTSS_USE_FTM0
|
||||
#define INPUT_CAPTURE_PIN 20 // receive (FTM0_CH5)
|
||||
#define OUTPUT_COMPARE_A_PIN 21 // transmit (FTM0_CH6)
|
||||
#define OUTPUT_COMPARE_B_PIN 22 // unusable PWM (FTM0_CH0)
|
||||
#define OUTPUT_COMPARE_C_PIN 23 // PWM usable fixed freq
|
||||
#define OUTPUT_COMPARE_D_PIN 5 // PWM usable fixed freq
|
||||
#define OUTPUT_COMPARE_E_PIN 6 // PWM usable fixed freq
|
||||
#define OUTPUT_COMPARE_F_PIN 9 // PWM usable fixed freq
|
||||
#define OUTPUT_COMPARE_G_PIN 10 // PWM usable fixed freq
|
||||
|
||||
|
||||
// Wiring-S
|
||||
//
|
||||
#elif defined(__AVR_ATmega644P__) && defined(WIRING)
|
||||
|
||||
#define ALTSS_USE_TIMER1
|
||||
#define INPUT_CAPTURE_PIN 6 // receive
|
||||
#define OUTPUT_COMPARE_A_PIN 5 // transmit
|
||||
#define OUTPUT_COMPARE_B_PIN 4 // unusable PWM
|
||||
|
||||
|
||||
|
||||
// Arduino Uno, Duemilanove, LilyPad, etc
|
||||
//
|
||||
#elif defined(__AVR_ATmega168__) || defined(__AVR_ATmega328P__)
|
||||
|
||||
#define ALTSS_USE_TIMER1
|
||||
#define INPUT_CAPTURE_PIN 8 // receive
|
||||
#define OUTPUT_COMPARE_A_PIN 9 // transmit
|
||||
#define OUTPUT_COMPARE_B_PIN 10 // unusable PWM
|
||||
|
||||
|
||||
// Arduino Leonardo & Yun (from Cristian Maglie)
|
||||
//
|
||||
#elif defined(ARDUINO_AVR_YUN) || defined(ARDUINO_AVR_LEONARDO) || defined(__AVR_ATmega32U4__)
|
||||
|
||||
//#define ALTSS_USE_TIMER1
|
||||
//#define INPUT_CAPTURE_PIN 4 // receive
|
||||
//#define OUTPUT_COMPARE_A_PIN 9 // transmit
|
||||
//#define OUTPUT_COMPARE_B_PIN 10 // unusable PWM
|
||||
//#define OUTPUT_COMPARE_C_PIN 11 // unusable PWM
|
||||
|
||||
#define ALTSS_USE_TIMER3
|
||||
#define INPUT_CAPTURE_PIN 13 // receive
|
||||
#define OUTPUT_COMPARE_A_PIN 5 // transmit
|
||||
|
||||
|
||||
// Arduino Mega
|
||||
//
|
||||
#elif defined(__AVR_ATmega1280__) || defined(__AVR_ATmega2560__)
|
||||
|
||||
//#define ALTSS_USE_TIMER4
|
||||
//#define INPUT_CAPTURE_PIN 49 // receive
|
||||
//#define OUTPUT_COMPARE_A_PIN 6 // transmit
|
||||
//#define OUTPUT_COMPARE_B_PIN 7 // unusable PWM
|
||||
//#define OUTPUT_COMPARE_C_PIN 8 // unusable PWM
|
||||
|
||||
#define ALTSS_USE_TIMER5
|
||||
#define INPUT_CAPTURE_PIN 48 // receive
|
||||
#define OUTPUT_COMPARE_A_PIN 46 // transmit
|
||||
#define OUTPUT_COMPARE_B_PIN 45 // unusable PWM
|
||||
#define OUTPUT_COMPARE_C_PIN 44 // unusable PWM
|
||||
|
||||
|
||||
|
||||
// Sanguino
|
||||
#elif defined(__AVR_ATmega644P__) || defined(__AVR_ATmega644__)
|
||||
#define ALTSS_USE_TIMER1
|
||||
#define INPUT_CAPTURE_PIN 14 // receive
|
||||
#define OUTPUT_COMPARE_A_PIN 13 // transmit
|
||||
#define OUTPUT_COMPARE_B_PIN 12 // unusable PWM
|
||||
|
||||
|
||||
// Unknown board
|
||||
#else
|
||||
#error "Please define your board timer and pins"
|
||||
#endif
|
||||
|
||||
@@ -0,0 +1,174 @@
|
||||
/* An Alternative Software Serial Library
|
||||
* http://www.pjrc.com/teensy/td_libs_AltSoftSerial.html
|
||||
* Copyright (c) 2014 PJRC.COM, LLC, Paul Stoffregen, paul@pjrc.com
|
||||
*
|
||||
* Permission is hereby granted, free of charge, to any person obtaining a copy
|
||||
* of this software and associated documentation files (the "Software"), to deal
|
||||
* in the Software without restriction, including without limitation the rights
|
||||
* to use, copy, modify, merge, publish, distribute, sublicense, and/or sell
|
||||
* copies of the Software, and to permit persons to whom the Software is
|
||||
* furnished to do so, subject to the following conditions:
|
||||
*
|
||||
* The above copyright notice and this permission notice shall be included in
|
||||
* all copies or substantial portions of the Software.
|
||||
*
|
||||
* THE SOFTWARE IS PROVIDED "AS IS", WITHOUT WARRANTY OF ANY KIND, EXPRESS OR
|
||||
* IMPLIED, INCLUDING BUT NOT LIMITED TO THE WARRANTIES OF MERCHANTABILITY,
|
||||
* FITNESS FOR A PARTICULAR PURPOSE AND NONINFRINGEMENT. IN NO EVENT SHALL THE
|
||||
* AUTHORS OR COPYRIGHT HOLDERS BE LIABLE FOR ANY CLAIM, DAMAGES OR OTHER
|
||||
* LIABILITY, WHETHER IN AN ACTION OF CONTRACT, TORT OR OTHERWISE, ARISING FROM,
|
||||
* OUT OF OR IN CONNECTION WITH THE SOFTWARE OR THE USE OR OTHER DEALINGS IN
|
||||
* THE SOFTWARE.
|
||||
*/
|
||||
|
||||
#if defined(ALTSS_USE_TIMER1)
|
||||
#define CONFIG_TIMER_NOPRESCALE() (TIMSK1 = 0, TCCR1A = 0, TCCR1B = (1<<ICNC1) | (1<<CS10))
|
||||
#define CONFIG_TIMER_PRESCALE_8() (TIMSK1 = 0, TCCR1A = 0, TCCR1B = (1<<ICNC1) | (1<<CS11))
|
||||
#define CONFIG_MATCH_NORMAL() (TCCR1A = TCCR1A & ~((1<<COM1A1) | (1<<COM1A0)))
|
||||
#define CONFIG_MATCH_TOGGLE() (TCCR1A = (TCCR1A & ~(1<<COM1A1)) | (1<<COM1A0))
|
||||
#define CONFIG_MATCH_CLEAR() (TCCR1A = (TCCR1A | (1<<COM1A1)) & ~(1<<COM1A0))
|
||||
#define CONFIG_MATCH_SET() (TCCR1A = TCCR1A | ((1<<COM1A1) | (1<<COM1A0)))
|
||||
#define CONFIG_CAPTURE_FALLING_EDGE() (TCCR1B &= ~(1<<ICES1))
|
||||
#define CONFIG_CAPTURE_RISING_EDGE() (TCCR1B |= (1<<ICES1))
|
||||
#define ENABLE_INT_INPUT_CAPTURE() (TIFR1 = (1<<ICF1), TIMSK1 = (1<<ICIE1))
|
||||
#define ENABLE_INT_COMPARE_A() (TIFR1 = (1<<OCF1A), TIMSK1 |= (1<<OCIE1A))
|
||||
#define ENABLE_INT_COMPARE_B() (TIFR1 = (1<<OCF1B), TIMSK1 |= (1<<OCIE1B))
|
||||
#define DISABLE_INT_INPUT_CAPTURE() (TIMSK1 &= ~(1<<ICIE1))
|
||||
#define DISABLE_INT_COMPARE_A() (TIMSK1 &= ~(1<<OCIE1A))
|
||||
#define DISABLE_INT_COMPARE_B() (TIMSK1 &= ~(1<<OCIE1B))
|
||||
#define GET_TIMER_COUNT() (TCNT1)
|
||||
#define GET_INPUT_CAPTURE() (ICR1)
|
||||
#define GET_COMPARE_A() (OCR1A)
|
||||
#define GET_COMPARE_B() (OCR1B)
|
||||
#define SET_COMPARE_A(val) (OCR1A = (val))
|
||||
#define SET_COMPARE_B(val) (OCR1B = (val))
|
||||
#define CAPTURE_INTERRUPT TIMER1_CAPT_vect
|
||||
#define COMPARE_A_INTERRUPT TIMER1_COMPA_vect
|
||||
#define COMPARE_B_INTERRUPT TIMER1_COMPB_vect
|
||||
|
||||
|
||||
#elif defined(ALTSS_USE_TIMER3)
|
||||
#define CONFIG_TIMER_NOPRESCALE() (TIMSK3 = 0, TCCR3A = 0, TCCR3B = (1<<ICNC3) | (1<<CS30))
|
||||
#define CONFIG_TIMER_PRESCALE_8() (TIMSK3 = 0, TCCR3A = 0, TCCR3B = (1<<ICNC3) | (1<<CS31))
|
||||
#define CONFIG_MATCH_NORMAL() (TCCR3A = TCCR3A & ~((1<<COM3A1) | (1<<COM3A0)))
|
||||
#define CONFIG_MATCH_TOGGLE() (TCCR3A = (TCCR3A & ~(1<<COM3A1)) | (1<<COM3A0))
|
||||
#define CONFIG_MATCH_CLEAR() (TCCR3A = (TCCR3A | (1<<COM3A1)) & ~(1<<COM3A0))
|
||||
#define CONFIG_MATCH_SET() (TCCR3A = TCCR3A | ((1<<COM3A1) | (1<<COM3A0)))
|
||||
#define CONFIG_CAPTURE_FALLING_EDGE() (TCCR3B &= ~(1<<ICES3))
|
||||
#define CONFIG_CAPTURE_RISING_EDGE() (TCCR3B |= (1<<ICES3))
|
||||
#define ENABLE_INT_INPUT_CAPTURE() (TIFR3 = (1<<ICF3), TIMSK3 = (1<<ICIE3))
|
||||
#define ENABLE_INT_COMPARE_A() (TIFR3 = (1<<OCF3A), TIMSK3 |= (1<<OCIE3A))
|
||||
#define ENABLE_INT_COMPARE_B() (TIFR3 = (1<<OCF3B), TIMSK3 |= (1<<OCIE3B))
|
||||
#define DISABLE_INT_INPUT_CAPTURE() (TIMSK3 &= ~(1<<ICIE3))
|
||||
#define DISABLE_INT_COMPARE_A() (TIMSK3 &= ~(1<<OCIE3A))
|
||||
#define DISABLE_INT_COMPARE_B() (TIMSK3 &= ~(1<<OCIE3B))
|
||||
#define GET_TIMER_COUNT() (TCNT3)
|
||||
#define GET_INPUT_CAPTURE() (ICR3)
|
||||
#define GET_COMPARE_A() (OCR3A)
|
||||
#define GET_COMPARE_B() (OCR3B)
|
||||
#define SET_COMPARE_A(val) (OCR3A = (val))
|
||||
#define SET_COMPARE_B(val) (OCR3B = (val))
|
||||
#define CAPTURE_INTERRUPT TIMER3_CAPT_vect
|
||||
#define COMPARE_A_INTERRUPT TIMER3_COMPA_vect
|
||||
#define COMPARE_B_INTERRUPT TIMER3_COMPB_vect
|
||||
|
||||
|
||||
#elif defined(ALTSS_USE_TIMER4)
|
||||
#define CONFIG_TIMER_NOPRESCALE() (TIMSK4 = 0, TCCR4A = 0, TCCR4B = (1<<ICNC4) | (1<<CS40))
|
||||
#define CONFIG_TIMER_PRESCALE_8() (TIMSK4 = 0, TCCR4A = 0, TCCR4B = (1<<ICNC4) | (1<<CS41))
|
||||
#define CONFIG_MATCH_NORMAL() (TCCR4A = TCCR4A & ~((1<<COM4A1) | (1<<COM4A0)))
|
||||
#define CONFIG_MATCH_TOGGLE() (TCCR4A = (TCCR4A & ~(1<<COM4A1)) | (1<<COM4A0))
|
||||
#define CONFIG_MATCH_CLEAR() (TCCR4A = (TCCR4A | (1<<COM4A1)) & ~(1<<COM4A0))
|
||||
#define CONFIG_MATCH_SET() (TCCR4A = TCCR4A | ((1<<COM4A1) | (1<<COM4A0)))
|
||||
#define CONFIG_CAPTURE_FALLING_EDGE() (TCCR4B &= ~(1<<ICES4))
|
||||
#define CONFIG_CAPTURE_RISING_EDGE() (TCCR4B |= (1<<ICES4))
|
||||
#define ENABLE_INT_INPUT_CAPTURE() (TIFR4 = (1<<ICF4), TIMSK4 = (1<<ICIE4))
|
||||
#define ENABLE_INT_COMPARE_A() (TIFR4 = (1<<OCF4A), TIMSK4 |= (1<<OCIE4A))
|
||||
#define ENABLE_INT_COMPARE_B() (TIFR4 = (1<<OCF4B), TIMSK4 |= (1<<OCIE4B))
|
||||
#define DISABLE_INT_INPUT_CAPTURE() (TIMSK4 &= ~(1<<ICIE4))
|
||||
#define DISABLE_INT_COMPARE_A() (TIMSK4 &= ~(1<<OCIE4A))
|
||||
#define DISABLE_INT_COMPARE_B() (TIMSK4 &= ~(1<<OCIE4B))
|
||||
#define GET_TIMER_COUNT() (TCNT4)
|
||||
#define GET_INPUT_CAPTURE() (ICR4)
|
||||
#define GET_COMPARE_A() (OCR4A)
|
||||
#define GET_COMPARE_B() (OCR4B)
|
||||
#define SET_COMPARE_A(val) (OCR4A = (val))
|
||||
#define SET_COMPARE_B(val) (OCR4B = (val))
|
||||
#define CAPTURE_INTERRUPT TIMER4_CAPT_vect
|
||||
#define COMPARE_A_INTERRUPT TIMER4_COMPA_vect
|
||||
#define COMPARE_B_INTERRUPT TIMER4_COMPB_vect
|
||||
|
||||
|
||||
#elif defined(ALTSS_USE_TIMER5)
|
||||
#define CONFIG_TIMER_NOPRESCALE() (TIMSK5 = 0, TCCR5A = 0, TCCR5B = (1<<ICNC5) | (1<<CS50))
|
||||
#define CONFIG_TIMER_PRESCALE_8() (TIMSK5 = 0, TCCR5A = 0, TCCR5B = (1<<ICNC5) | (1<<CS51))
|
||||
#define CONFIG_MATCH_NORMAL() (TCCR5A = TCCR5A & ~((1<<COM5A1) | (1<<COM5A0)))
|
||||
#define CONFIG_MATCH_TOGGLE() (TCCR5A = (TCCR5A & ~(1<<COM5A1)) | (1<<COM5A0))
|
||||
#define CONFIG_MATCH_CLEAR() (TCCR5A = (TCCR5A | (1<<COM5A1)) & ~(1<<COM5A0))
|
||||
#define CONFIG_MATCH_SET() (TCCR5A = TCCR5A | ((1<<COM5A1) | (1<<COM5A0)))
|
||||
#define CONFIG_CAPTURE_FALLING_EDGE() (TCCR5B &= ~(1<<ICES5))
|
||||
#define CONFIG_CAPTURE_RISING_EDGE() (TCCR5B |= (1<<ICES5))
|
||||
#define ENABLE_INT_INPUT_CAPTURE() (TIFR5 = (1<<ICF5), TIMSK5 = (1<<ICIE5))
|
||||
#define ENABLE_INT_COMPARE_A() (TIFR5 = (1<<OCF5A), TIMSK5 |= (1<<OCIE5A))
|
||||
#define ENABLE_INT_COMPARE_B() (TIFR5 = (1<<OCF5B), TIMSK5 |= (1<<OCIE5B))
|
||||
#define DISABLE_INT_INPUT_CAPTURE() (TIMSK5 &= ~(1<<ICIE5))
|
||||
#define DISABLE_INT_COMPARE_A() (TIMSK5 &= ~(1<<OCIE5A))
|
||||
#define DISABLE_INT_COMPARE_B() (TIMSK5 &= ~(1<<OCIE5B))
|
||||
#define GET_TIMER_COUNT() (TCNT5)
|
||||
#define GET_INPUT_CAPTURE() (ICR5)
|
||||
#define GET_COMPARE_A() (OCR5A)
|
||||
#define GET_COMPARE_B() (OCR5B)
|
||||
#define SET_COMPARE_A(val) (OCR5A = (val))
|
||||
#define SET_COMPARE_B(val) (OCR5B = (val))
|
||||
#define CAPTURE_INTERRUPT TIMER5_CAPT_vect
|
||||
#define COMPARE_A_INTERRUPT TIMER5_COMPA_vect
|
||||
#define COMPARE_B_INTERRUPT TIMER5_COMPB_vect
|
||||
|
||||
|
||||
#elif defined(ALTSS_USE_FTM0)
|
||||
// CH5 = input capture (input, pin 20)
|
||||
// CH6 = compare a (output, pin 21)
|
||||
// CH0 = compare b (input timeout)
|
||||
#define CONFIG_TIMER_NOPRESCALE() FTM0_SC = 0; FTM0_CNT = 0; FTM0_MOD = 0xFFFF; \
|
||||
FTM0_SC = FTM_SC_CLKS(1) | FTM_SC_PS(0); \
|
||||
digitalWriteFast(21, HIGH); \
|
||||
NVIC_SET_PRIORITY(IRQ_FTM0, 48); \
|
||||
NVIC_ENABLE_IRQ(IRQ_FTM0);
|
||||
#define CONFIG_TIMER_PRESCALE_8() FTM0_SC = 0; FTM0_CNT = 0; FTM0_MOD = 0xFFFF; \
|
||||
FTM0_SC = FTM_SC_CLKS(1) | FTM_SC_PS(3); \
|
||||
digitalWriteFast(21, HIGH); \
|
||||
NVIC_SET_PRIORITY(IRQ_FTM0, 48); \
|
||||
NVIC_ENABLE_IRQ(IRQ_FTM0);
|
||||
#define CONFIG_MATCH_NORMAL() (FTM0_C6SC = 0)
|
||||
#define CONFIG_MATCH_TOGGLE() (FTM0_C6SC = (FTM0_C6SC & 0xC3) | 0x14)
|
||||
#define CONFIG_MATCH_CLEAR() (FTM0_C6SC = (FTM0_C6SC & 0xC3) | 0x18)
|
||||
#define CONFIG_MATCH_SET() (FTM0_C6SC = (FTM0_C6SC & 0xC3) | 0x1C)
|
||||
#define CONFIG_CAPTURE_FALLING_EDGE() (FTM0_C5SC = (FTM0_C5SC & 0xC3) | 0x08)
|
||||
#define CONFIG_CAPTURE_RISING_EDGE() (FTM0_C5SC = (FTM0_C5SC & 0xC3) | 0x04)
|
||||
#define ENABLE_INT_INPUT_CAPTURE() FTM0_C5SC = 0x48; \
|
||||
CORE_PIN20_CONFIG = PORT_PCR_MUX(4)|PORT_PCR_PE|PORT_PCR_PS
|
||||
#define ENABLE_INT_COMPARE_A() FTM0_C6SC |= 0x40; \
|
||||
CORE_PIN21_CONFIG = PORT_PCR_MUX(4)|PORT_PCR_DSE|PORT_PCR_SRE
|
||||
#define ENABLE_INT_COMPARE_B() (FTM0_C0SC |= 0x40)
|
||||
#define DISABLE_INT_INPUT_CAPTURE() FTM0_C5SC &= ~0x40; \
|
||||
CORE_PIN20_CONFIG = PORT_PCR_MUX(1)|PORT_PCR_PE|PORT_PCR_PS
|
||||
#define DISABLE_INT_COMPARE_A() FTM0_C6SC &= ~0x40; \
|
||||
CORE_PIN21_CONFIG = PORT_PCR_MUX(1)|PORT_PCR_DSE|PORT_PCR_SRE; \
|
||||
digitalWriteFast(21, HIGH)
|
||||
#define DISABLE_INT_COMPARE_B() (FTM0_C0SC &= ~0x40)
|
||||
#define GET_TIMER_COUNT() (FTM0_CNT)
|
||||
#define GET_INPUT_CAPTURE() (FTM0_C5V)
|
||||
#define GET_COMPARE_A() (FTM0_C6V)
|
||||
#define GET_COMPARE_B() (FTM0_C0V)
|
||||
#define SET_COMPARE_A(val) (FTM0_C6V = val)
|
||||
#define SET_COMPARE_B(val) (FTM0_C0V = val)
|
||||
#define CAPTURE_INTERRUPT altss_capture_interrupt
|
||||
#define COMPARE_A_INTERRUPT altss_compare_a_interrupt
|
||||
#define COMPARE_B_INTERRUPT altss_compare_b_interrupt
|
||||
#ifdef ISR
|
||||
#undef ISR
|
||||
#endif
|
||||
#define ISR(f) static void f (void)
|
||||
|
||||
|
||||
#endif
|
||||
@@ -0,0 +1,103 @@
|
||||
|
||||
|
||||
// Teensy 2.0
|
||||
//
|
||||
#if defined(__AVR_ATmega32U4__) && defined(CORE_TEENSY)
|
||||
|
||||
//#define ALTSS_USE_TIMER1
|
||||
//#define INPUT_CAPTURE_PIN 22 // receive
|
||||
//#define OUTPUT_COMPARE_A_PIN 14 // transmit
|
||||
//#define OUTPUT_COMPARE_B_PIN 15 // unusable PWM
|
||||
//#define OUTPUT_COMPARE_C_PIN 4 // unusable PWM
|
||||
|
||||
#define ALTSS_USE_TIMER3
|
||||
#define INPUT_CAPTURE_PIN 10 // receive
|
||||
#define OUTPUT_COMPARE_A_PIN 9 // transmit
|
||||
|
||||
|
||||
|
||||
// Teensy++ 2.0
|
||||
//
|
||||
#elif defined(__AVR_AT90USB1286__) && defined(CORE_TEENSY)
|
||||
|
||||
#define ALTSS_USE_TIMER1
|
||||
#define INPUT_CAPTURE_PIN 4 // receive
|
||||
#define OUTPUT_COMPARE_A_PIN 25 // transmit
|
||||
#define OUTPUT_COMPARE_B_PIN 26 // unusable PWM
|
||||
#define OUTPUT_COMPARE_C_PIN 27 // unusable PWM
|
||||
|
||||
//#define ALTSS_USE_TIMER3
|
||||
//#define INPUT_CAPTURE_PIN 17 // receive
|
||||
//#define OUTPUT_COMPARE_A_PIN 16 // transmit
|
||||
//#define OUTPUT_COMPARE_B_PIN 15 // unusable PWM
|
||||
//#define OUTPUT_COMPARE_C_PIN 14 // unusable PWM
|
||||
|
||||
|
||||
|
||||
// Wiring-S
|
||||
//
|
||||
#elif defined(__AVR_ATmega644P__) && defined(WIRING)
|
||||
|
||||
#define ALTSS_USE_TIMER1
|
||||
#define INPUT_CAPTURE_PIN 6 // receive
|
||||
#define OUTPUT_COMPARE_A_PIN 5 // transmit
|
||||
#define OUTPUT_COMPARE_B_PIN 4 // unusable PWM
|
||||
|
||||
|
||||
|
||||
// Arduino Uno, Duemilanove, LilyPad, etc
|
||||
//
|
||||
#elif defined(__AVR_ATmega168__) || defined(__AVR_ATmega328P__)
|
||||
|
||||
#define ALTSS_USE_TIMER1
|
||||
#define INPUT_CAPTURE_PIN 8 // receive
|
||||
#define OUTPUT_COMPARE_A_PIN 9 // transmit
|
||||
#define OUTPUT_COMPARE_B_PIN 10 // unusable PWM
|
||||
|
||||
|
||||
// Arduino Leonardo & Yun (from Cristian Maglie)
|
||||
//
|
||||
#elif defined(ARDUINO_AVR_YUN) || defined(ARDUINO_AVR_LEONARDO)
|
||||
|
||||
//#define ALTSS_USE_TIMER1
|
||||
//#define INPUT_CAPTURE_PIN 4 // receive
|
||||
//#define OUTPUT_COMPARE_A_PIN 9 // transmit
|
||||
//#define OUTPUT_COMPARE_B_PIN 10 // unusable PWM
|
||||
//#define OUTPUT_COMPARE_C_PIN 11 // unusable PWM
|
||||
|
||||
#define ALTSS_USE_TIMER3
|
||||
#define INPUT_CAPTURE_PIN 13 // receive
|
||||
#define OUTPUT_COMPARE_A_PIN 5 // transmit
|
||||
|
||||
|
||||
// Arduino Mega
|
||||
//
|
||||
#elif defined(__AVR_ATmega1280__) || defined(__AVR_ATmega2560__)
|
||||
|
||||
//#define ALTSS_USE_TIMER4
|
||||
//#define INPUT_CAPTURE_PIN 49 // receive
|
||||
//#define OUTPUT_COMPARE_A_PIN 6 // transmit
|
||||
//#define OUTPUT_COMPARE_B_PIN 7 // unusable PWM
|
||||
//#define OUTPUT_COMPARE_C_PIN 8 // unusable PWM
|
||||
|
||||
#define ALTSS_USE_TIMER5
|
||||
#define INPUT_CAPTURE_PIN 48 // receive
|
||||
#define OUTPUT_COMPARE_A_PIN 46 // transmit
|
||||
#define OUTPUT_COMPARE_B_PIN 45 // unusable PWM
|
||||
#define OUTPUT_COMPARE_C_PIN 44 // unusable PWM
|
||||
|
||||
|
||||
|
||||
// Sanguino
|
||||
#elif defined(__AVR_ATmega644P__) || defined(__AVR_ATmega644__)
|
||||
#define ALTSS_USE_TIMER1
|
||||
#define INPUT_CAPTURE_PIN 14 // receive
|
||||
#define OUTPUT_COMPARE_A_PIN 13 // transmit
|
||||
#define OUTPUT_COMPARE_B_PIN 12 // unusable PWM
|
||||
|
||||
|
||||
// Unknown board
|
||||
#else
|
||||
#error "Please define your board timer and pins"
|
||||
#endif
|
||||
|
||||
@@ -0,0 +1,106 @@
|
||||
|
||||
#if defined(ALTSS_USE_TIMER1)
|
||||
#define CONFIG_TIMER_NOPRESCALE() (TIMSK1 = 0, TCCR1A = 0, TCCR1B = (1<<ICNC1) | (1<<CS10))
|
||||
#define CONFIG_TIMER_PRESCALE_8() (TIMSK1 = 0, TCCR1A = 0, TCCR1B = (1<<ICNC1) | (1<<CS11))
|
||||
#define CONFIG_MATCH_NORMAL() (TCCR1A = TCCR1A & ~((1<<COM1A1) | (1<<COM1A0)))
|
||||
#define CONFIG_MATCH_TOGGLE() (TCCR1A = (TCCR1A & ~(1<<COM1A1)) | (1<<COM1A0))
|
||||
#define CONFIG_MATCH_CLEAR() (TCCR1A = (TCCR1A | (1<<COM1A1)) & ~(1<<COM1A0))
|
||||
#define CONFIG_MATCH_SET() (TCCR1A = TCCR1A | ((1<<COM1A1) | (1<<COM1A0)))
|
||||
#define CONFIG_CAPTURE_FALLING_EDGE() (TCCR1B &= ~(1<<ICES1))
|
||||
#define CONFIG_CAPTURE_RISING_EDGE() (TCCR1B |= (1<<ICES1))
|
||||
#define ENABLE_INT_INPUT_CAPTURE() (TIFR1 = (1<<ICF1), TIMSK1 = (1<<ICIE1))
|
||||
#define ENABLE_INT_COMPARE_A() (TIFR1 = (1<<OCF1A), TIMSK1 |= (1<<OCIE1A))
|
||||
#define ENABLE_INT_COMPARE_B() (TIFR1 = (1<<OCF1B), TIMSK1 |= (1<<OCIE1B))
|
||||
#define DISABLE_INT_INPUT_CAPTURE() (TIMSK1 &= ~(1<<ICIE1))
|
||||
#define DISABLE_INT_COMPARE_A() (TIMSK1 &= ~(1<<OCIE1A))
|
||||
#define DISABLE_INT_COMPARE_B() (TIMSK1 &= ~(1<<OCIE1B))
|
||||
#define GET_TIMER_COUNT() (TCNT1)
|
||||
#define GET_INPUT_CAPTURE() (ICR1)
|
||||
#define GET_COMPARE_A() (OCR1A)
|
||||
#define GET_COMPARE_B() (OCR1B)
|
||||
#define SET_COMPARE_A(val) (OCR1A = (val))
|
||||
#define SET_COMPARE_B(val) (OCR1B = (val))
|
||||
#define CAPTURE_INTERRUPT TIMER1_CAPT_vect
|
||||
#define COMPARE_A_INTERRUPT TIMER1_COMPA_vect
|
||||
#define COMPARE_B_INTERRUPT TIMER1_COMPB_vect
|
||||
|
||||
|
||||
#elif defined(ALTSS_USE_TIMER3)
|
||||
#define CONFIG_TIMER_NOPRESCALE() (TIMSK3 = 0, TCCR3A = 0, TCCR3B = (1<<ICNC3) | (1<<CS30))
|
||||
#define CONFIG_TIMER_PRESCALE_8() (TIMSK3 = 0, TCCR3A = 0, TCCR3B = (1<<ICNC3) | (1<<CS31))
|
||||
#define CONFIG_MATCH_NORMAL() (TCCR3A = TCCR3A & ~((1<<COM3A1) | (1<<COM3A0)))
|
||||
#define CONFIG_MATCH_TOGGLE() (TCCR3A = (TCCR3A & ~(1<<COM3A1)) | (1<<COM3A0))
|
||||
#define CONFIG_MATCH_CLEAR() (TCCR3A = (TCCR3A | (1<<COM3A1)) & ~(1<<COM3A0))
|
||||
#define CONFIG_MATCH_SET() (TCCR3A = TCCR3A | ((1<<COM3A1) | (1<<COM3A0)))
|
||||
#define CONFIG_CAPTURE_FALLING_EDGE() (TCCR3B &= ~(1<<ICES3))
|
||||
#define CONFIG_CAPTURE_RISING_EDGE() (TCCR3B |= (1<<ICES3))
|
||||
#define ENABLE_INT_INPUT_CAPTURE() (TIFR3 = (1<<ICF3), TIMSK3 = (1<<ICIE3))
|
||||
#define ENABLE_INT_COMPARE_A() (TIFR3 = (1<<OCF3A), TIMSK3 |= (1<<OCIE3A))
|
||||
#define ENABLE_INT_COMPARE_B() (TIFR3 = (1<<OCF3B), TIMSK3 |= (1<<OCIE3B))
|
||||
#define DISABLE_INT_INPUT_CAPTURE() (TIMSK3 &= ~(1<<ICIE3))
|
||||
#define DISABLE_INT_COMPARE_A() (TIMSK3 &= ~(1<<OCIE3A))
|
||||
#define DISABLE_INT_COMPARE_B() (TIMSK3 &= ~(1<<OCIE3B))
|
||||
#define GET_TIMER_COUNT() (TCNT3)
|
||||
#define GET_INPUT_CAPTURE() (ICR3)
|
||||
#define GET_COMPARE_A() (OCR3A)
|
||||
#define GET_COMPARE_B() (OCR3B)
|
||||
#define SET_COMPARE_A(val) (OCR3A = (val))
|
||||
#define SET_COMPARE_B(val) (OCR3B = (val))
|
||||
#define CAPTURE_INTERRUPT TIMER3_CAPT_vect
|
||||
#define COMPARE_A_INTERRUPT TIMER3_COMPA_vect
|
||||
#define COMPARE_B_INTERRUPT TIMER3_COMPB_vect
|
||||
|
||||
|
||||
#elif defined(ALTSS_USE_TIMER4)
|
||||
#define CONFIG_TIMER_NOPRESCALE() (TIMSK4 = 0, TCCR4A = 0, TCCR4B = (1<<ICNC4) | (1<<CS40))
|
||||
#define CONFIG_TIMER_PRESCALE_8() (TIMSK4 = 0, TCCR4A = 0, TCCR4B = (1<<ICNC4) | (1<<CS41))
|
||||
#define CONFIG_MATCH_NORMAL() (TCCR4A = TCCR4A & ~((1<<COM4A1) | (1<<COM4A0)))
|
||||
#define CONFIG_MATCH_TOGGLE() (TCCR4A = (TCCR4A & ~(1<<COM4A1)) | (1<<COM4A0))
|
||||
#define CONFIG_MATCH_CLEAR() (TCCR4A = (TCCR4A | (1<<COM4A1)) & ~(1<<COM4A0))
|
||||
#define CONFIG_MATCH_SET() (TCCR4A = TCCR4A | ((1<<COM4A1) | (1<<COM4A0)))
|
||||
#define CONFIG_CAPTURE_FALLING_EDGE() (TCCR4B &= ~(1<<ICES4))
|
||||
#define CONFIG_CAPTURE_RISING_EDGE() (TCCR4B |= (1<<ICES4))
|
||||
#define ENABLE_INT_INPUT_CAPTURE() (TIFR4 = (1<<ICF4), TIMSK4 = (1<<ICIE4))
|
||||
#define ENABLE_INT_COMPARE_A() (TIFR4 = (1<<OCF4A), TIMSK4 |= (1<<OCIE4A))
|
||||
#define ENABLE_INT_COMPARE_B() (TIFR4 = (1<<OCF4B), TIMSK4 |= (1<<OCIE4B))
|
||||
#define DISABLE_INT_INPUT_CAPTURE() (TIMSK4 &= ~(1<<ICIE4))
|
||||
#define DISABLE_INT_COMPARE_A() (TIMSK4 &= ~(1<<OCIE4A))
|
||||
#define DISABLE_INT_COMPARE_B() (TIMSK4 &= ~(1<<OCIE4B))
|
||||
#define GET_TIMER_COUNT() (TCNT4)
|
||||
#define GET_INPUT_CAPTURE() (ICR4)
|
||||
#define GET_COMPARE_A() (OCR4A)
|
||||
#define GET_COMPARE_B() (OCR4B)
|
||||
#define SET_COMPARE_A(val) (OCR4A = (val))
|
||||
#define SET_COMPARE_B(val) (OCR4B = (val))
|
||||
#define CAPTURE_INTERRUPT TIMER4_CAPT_vect
|
||||
#define COMPARE_A_INTERRUPT TIMER4_COMPA_vect
|
||||
#define COMPARE_B_INTERRUPT TIMER4_COMPB_vect
|
||||
|
||||
|
||||
#elif defined(ALTSS_USE_TIMER5)
|
||||
#define CONFIG_TIMER_NOPRESCALE() (TIMSK5 = 0, TCCR5A = 0, TCCR5B = (1<<ICNC5) | (1<<CS50))
|
||||
#define CONFIG_TIMER_PRESCALE_8() (TIMSK5 = 0, TCCR5A = 0, TCCR5B = (1<<ICNC5) | (1<<CS51))
|
||||
#define CONFIG_MATCH_NORMAL() (TCCR5A = TCCR5A & ~((1<<COM5A1) | (1<<COM5A0)))
|
||||
#define CONFIG_MATCH_TOGGLE() (TCCR5A = (TCCR5A & ~(1<<COM5A1)) | (1<<COM5A0))
|
||||
#define CONFIG_MATCH_CLEAR() (TCCR5A = (TCCR5A | (1<<COM5A1)) & ~(1<<COM5A0))
|
||||
#define CONFIG_MATCH_SET() (TCCR5A = TCCR5A | ((1<<COM5A1) | (1<<COM5A0)))
|
||||
#define CONFIG_CAPTURE_FALLING_EDGE() (TCCR5B &= ~(1<<ICES5))
|
||||
#define CONFIG_CAPTURE_RISING_EDGE() (TCCR5B |= (1<<ICES5))
|
||||
#define ENABLE_INT_INPUT_CAPTURE() (TIFR5 = (1<<ICF5), TIMSK5 = (1<<ICIE5))
|
||||
#define ENABLE_INT_COMPARE_A() (TIFR5 = (1<<OCF5A), TIMSK5 |= (1<<OCIE5A))
|
||||
#define ENABLE_INT_COMPARE_B() (TIFR5 = (1<<OCF5B), TIMSK5 |= (1<<OCIE5B))
|
||||
#define DISABLE_INT_INPUT_CAPTURE() (TIMSK5 &= ~(1<<ICIE5))
|
||||
#define DISABLE_INT_COMPARE_A() (TIMSK5 &= ~(1<<OCIE5A))
|
||||
#define DISABLE_INT_COMPARE_B() (TIMSK5 &= ~(1<<OCIE5B))
|
||||
#define GET_TIMER_COUNT() (TCNT5)
|
||||
#define GET_INPUT_CAPTURE() (ICR5)
|
||||
#define GET_COMPARE_A() (OCR5A)
|
||||
#define GET_COMPARE_B() (OCR5B)
|
||||
#define SET_COMPARE_A(val) (OCR5A = (val))
|
||||
#define SET_COMPARE_B(val) (OCR5B = (val))
|
||||
#define CAPTURE_INTERRUPT TIMER5_CAPT_vect
|
||||
#define COMPARE_A_INTERRUPT TIMER5_COMPA_vect
|
||||
#define COMPARE_B_INTERRUPT TIMER5_COMPB_vect
|
||||
|
||||
|
||||
#endif
|
||||
@@ -0,0 +1,38 @@
|
||||
#include <AltSoftSerial.h>
|
||||
|
||||
// AltSoftSerial always uses these pins:
|
||||
//
|
||||
// Board Transmit Receive PWM Unusable
|
||||
// ----- -------- ------- ------------
|
||||
// Teensy 3.0 & 3.1 21 20 22
|
||||
// Teensy 2.0 9 10 (none)
|
||||
// Teensy++ 2.0 25 4 26, 27
|
||||
// Arduino Uno 9 8 10
|
||||
// Arduino Leonardo 5 13 (none)
|
||||
// Arduino Mega 46 48 44, 45
|
||||
// Wiring-S 5 6 4
|
||||
// Sanguino 13 14 12
|
||||
|
||||
AltSoftSerial altSerial;
|
||||
|
||||
void setup() {
|
||||
Serial.begin(9600);
|
||||
while (!Serial) ; // wait for Arduino Serial Monitor to open
|
||||
Serial.println("AltSoftSerial Test Begin");
|
||||
altSerial.begin(9600);
|
||||
altSerial.println("Hello World");
|
||||
}
|
||||
|
||||
void loop() {
|
||||
char c;
|
||||
|
||||
if (Serial.available()) {
|
||||
c = Serial.read();
|
||||
altSerial.print(c);
|
||||
}
|
||||
if (altSerial.available()) {
|
||||
c = altSerial.read();
|
||||
Serial.print(c);
|
||||
}
|
||||
}
|
||||
|
||||
@@ -0,0 +1,4 @@
|
||||
AltSoftSerial KEYWORD1
|
||||
active KEYWORD2
|
||||
overflow KEYWORD2
|
||||
library_version KEYWORD2
|
||||
Reference in New Issue
Block a user